Conference Program
Plenary talks at ICM2027.
Plenary Talks
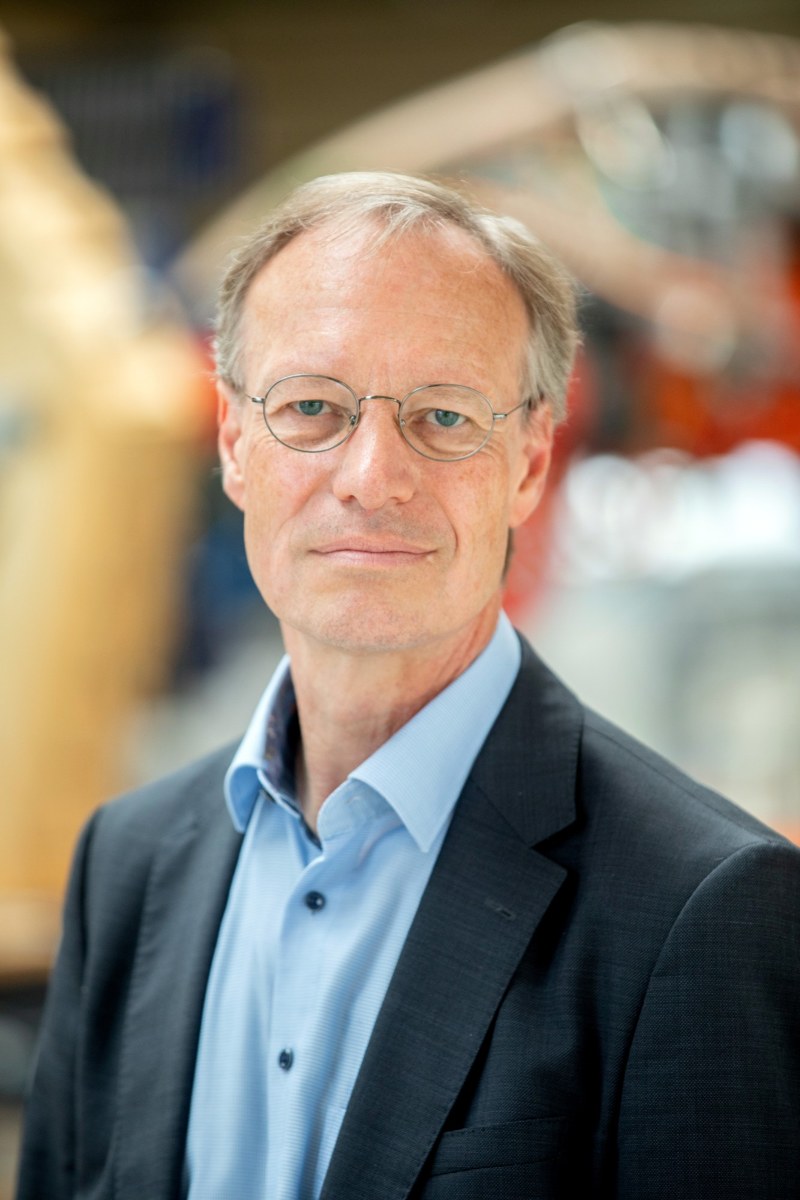
Title: Modeling, Estimation and Control of Soft Robotic Systems
Prof. Dr.-Ing. Oliver Sawodny
Institute for System Dynamics, University of Stuttgart, Germany
Abstract:
Compared to rigid-link robots, continuum robots offer advantages in navigation within confined spaces as well as in human-robot collaboration, and represent a current and active field of research. These systems can be actuated very efficiently, primarily using pneumatic bellows, muscles, or tubes. In this presentation, kinematic and dynamic models of these structures, including the pneumatic actuation, will be derived and discussed. Building on this, approaches for controlling both free trajectory tracking movement and movement in contact situations are presented. The approaches follow cascaded MIMO principles with Feedforward control in combination with feedback. Particular attention is given to the inherent coupling of the segments of the continuum manipulator. Various control concepts are introduced and discussed based on measurement data. In addition to the manipulator, soft structures as end-effectors also play a significant role in manipulation. A soft hand and its control system are presented in this context.
Speaker Bio:
Professor Sawodny received his Dipl.-Ing. degree in electrical engineering from the University of Karlsruhe, Germany, in 1991 and his Ph.D. degree from the University of Ulm, Germany, in 1996. In 2002, he became a Full Professor at the Technical University of Ilmenau, Germany. Since 2005, he has been the Director of the Institute for System Dynamics, University of Stuttgart, Stuttgart, Germany. His current research interests include methods of differential geometry, trajectory generation, and applications to mechatronic systems. He received important paper awards in major control application journals such as IEEE Transaction on Control System Technology Outstanding Paper Award (2013), and Control Engineering Practice Award 2024. He is a senior member of IEEE and EiC of IFAC Journal Mechatronics.